Onboard autonomy for ground
vehicles and surface vessels.

ARES brings platform control, navigation and mission execution into a common autonomy architecture.

It supports direct control and autonomous functions within the operating boundaries established for each platform.

PLATFORM AUTONOMY

Bring the platform’s essential functions together.

ARES integrates the functions required to control and operate an autonomous ground vehicle or surface vessel around the task.

Platform Control

Interface with propulsion, steering, braking and other platform-specific controls.
Navigation & Avoidance

Support route execution and obstacle avoidance using configured sensors and navigation inputs.
Mission Equipment

Integrate sensors, communications and payload functions around the mission.
Operator Command

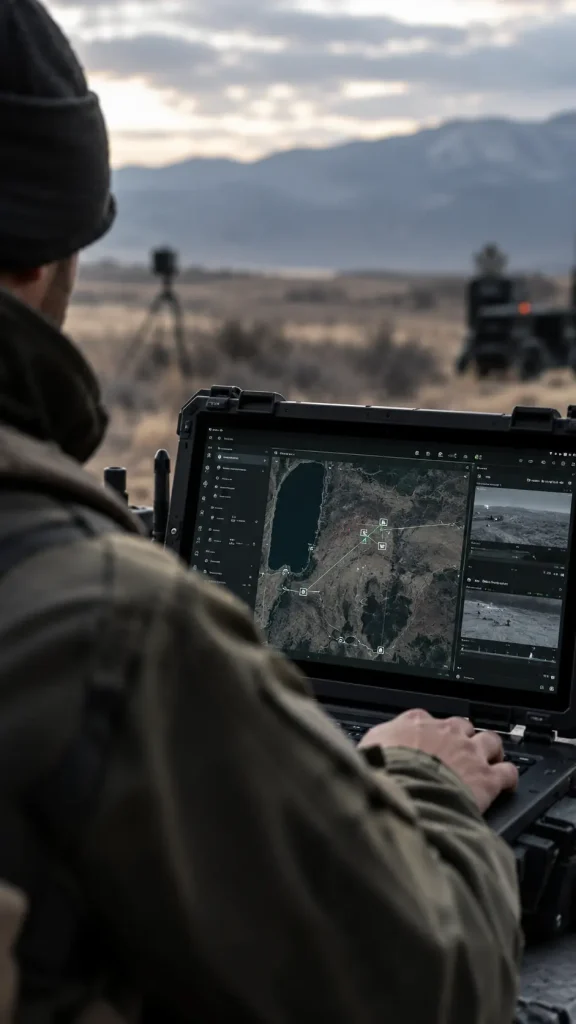
Exchange commands, platform status and mission information with the operator environment.
OPERATING MODES

Select the level of control
required for the task.

ARES supports different levels of platform control depending on the mission, platform configuration and operating environment.

Manual Control

The operator commands the platform directly.

Supervised Autonomy

The platform performs navigation and assigned functions under operator oversight.

Autonomous Execution

The platform carries out defined tasks within operator-approved boundaries.

DEGRADED OPERATION

Maintain defined behaviour when conditions change.

Predefined fallback and recovery behaviours can address faults, communications loss or degraded navigation inputs.

Available functions, operating limits and recovery behaviour are established for each platform configuration.

OPERATOR AUTHORITY

Autonomy within defined boundaries.

ARES automates platform-level functions while preserving operator authority over how the system is used.

Operating modes, intervention arrangements and autonomous boundaries are established around the platform, mission and operating environment.

APPLICATIONS

A common autonomy foundation across land and maritime surface platforms.

ARES provides onboard autonomy for applicable ground vehicles and surface vessels across the Milanion Advanced Systems portfolio.

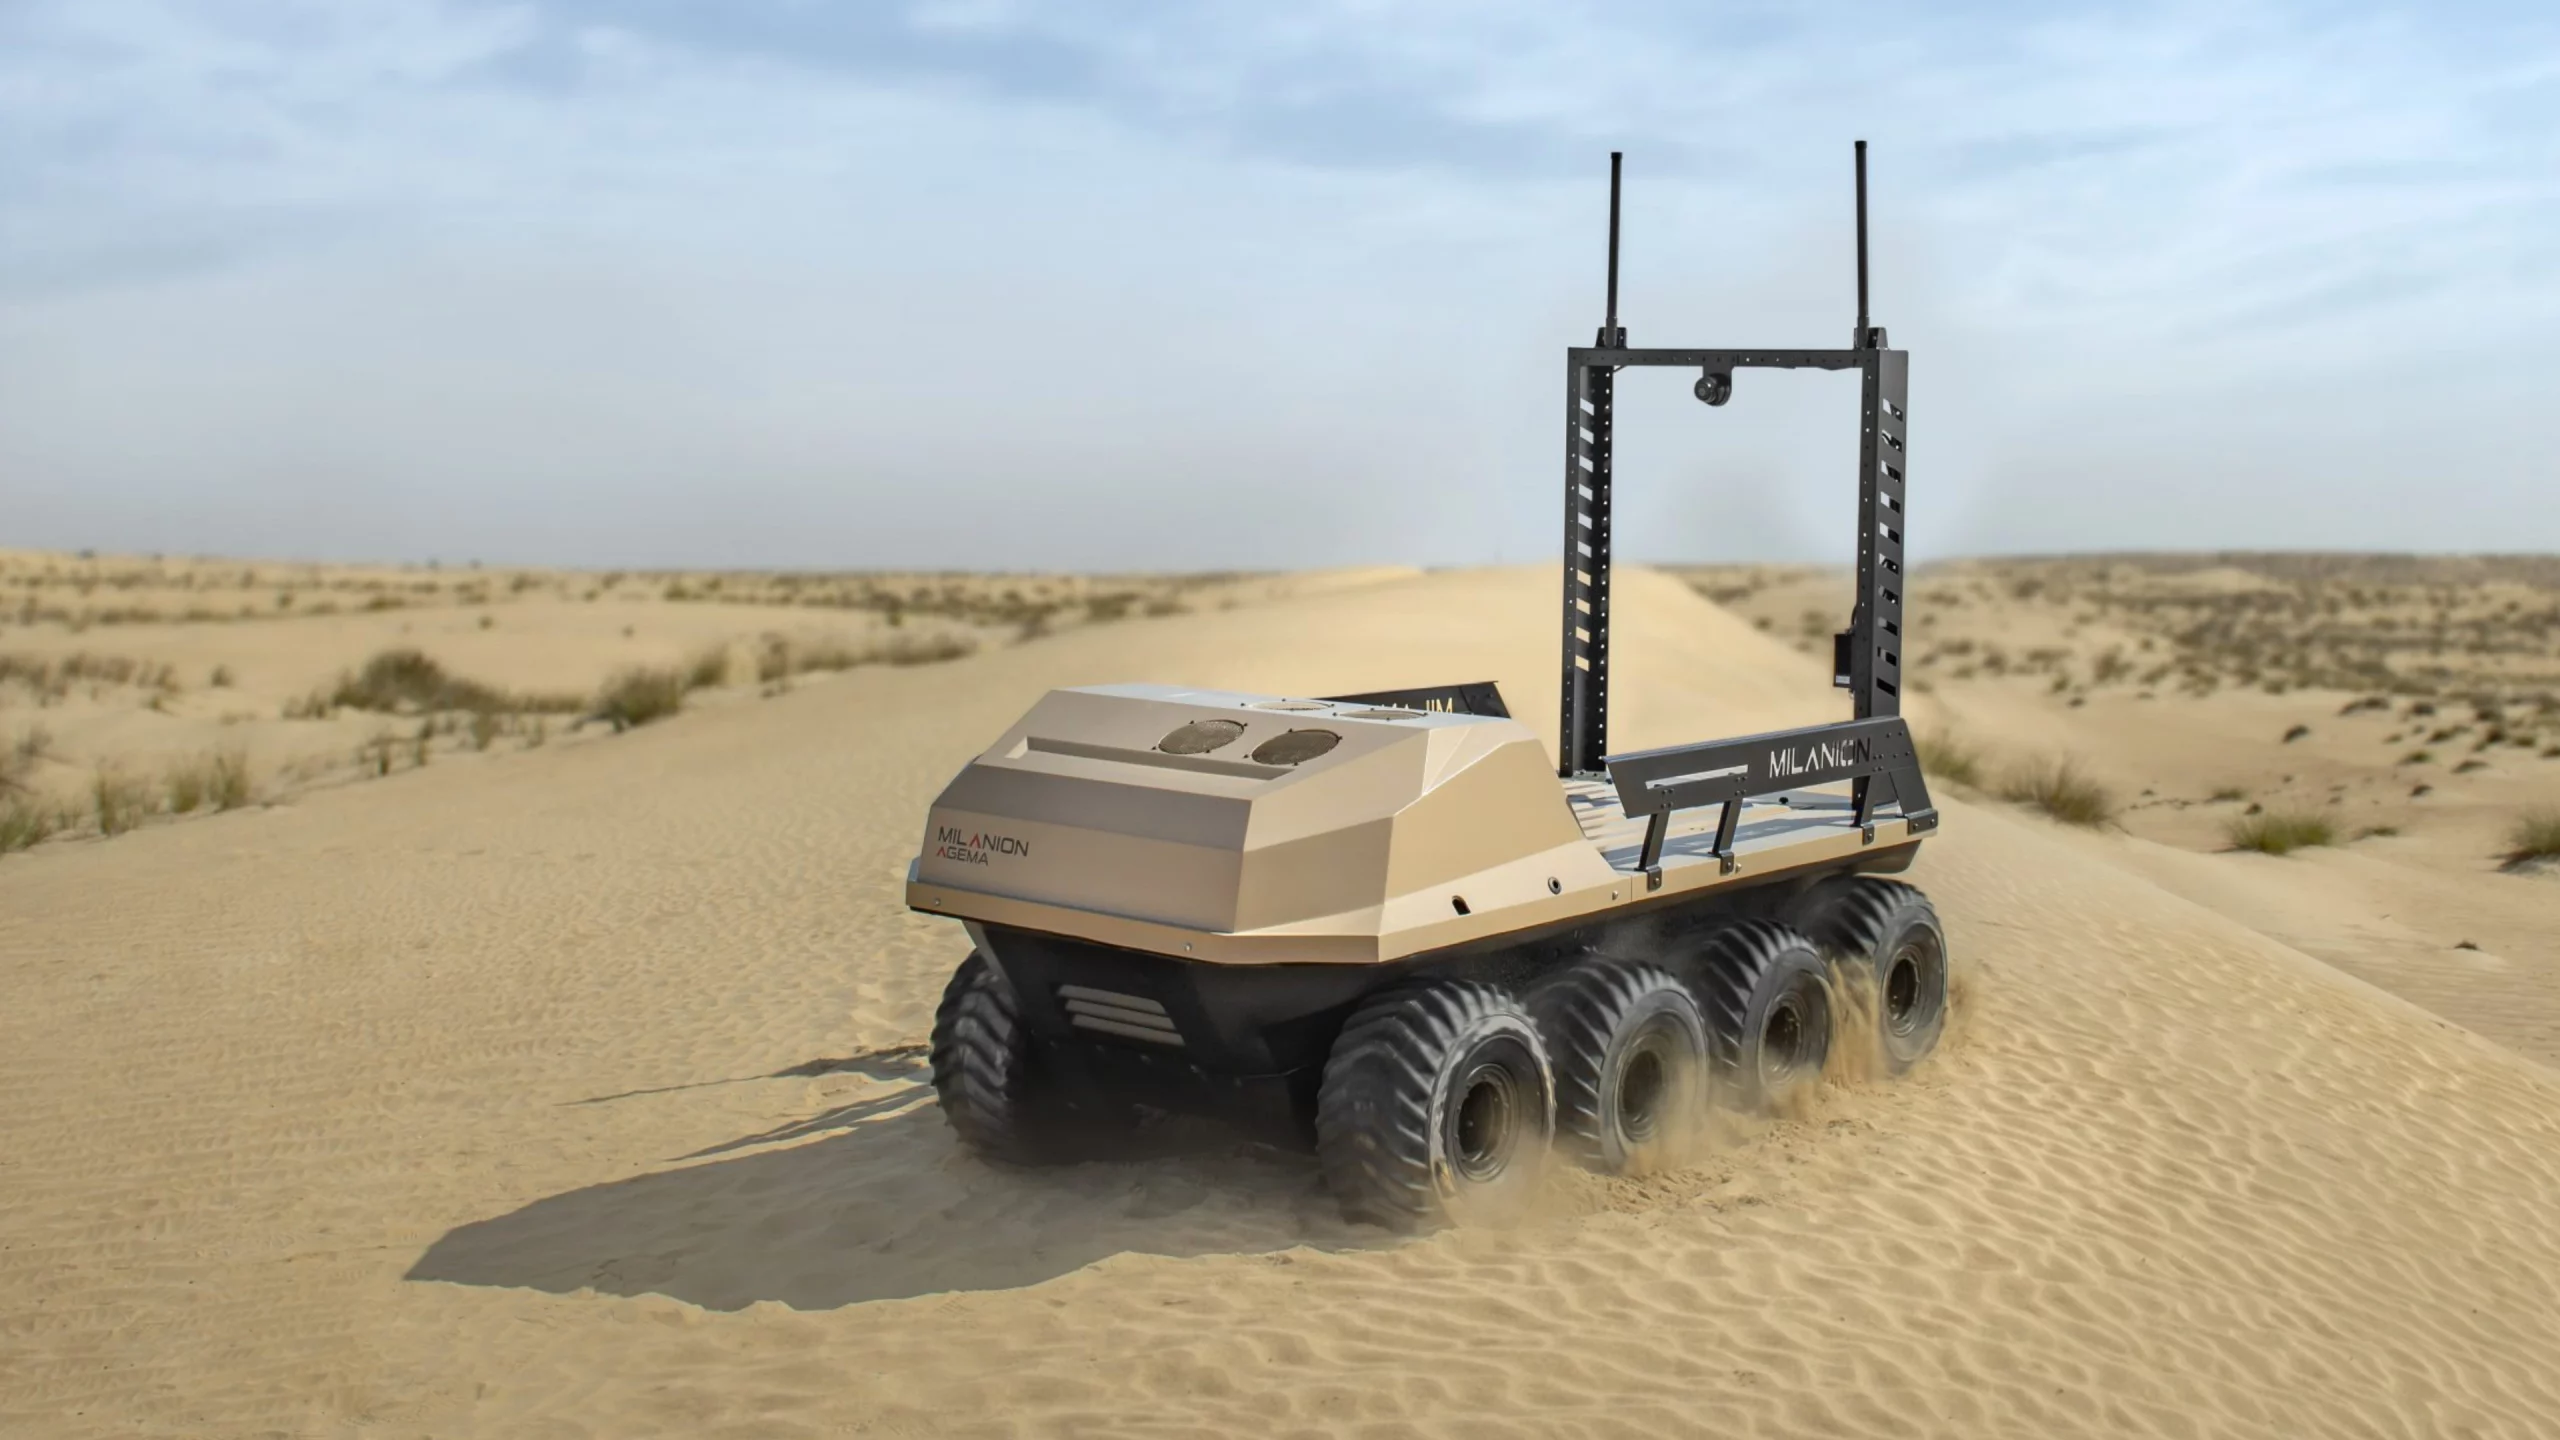
AGEMA UGV

Modular uncrewed ground vehicle.

HUDOR

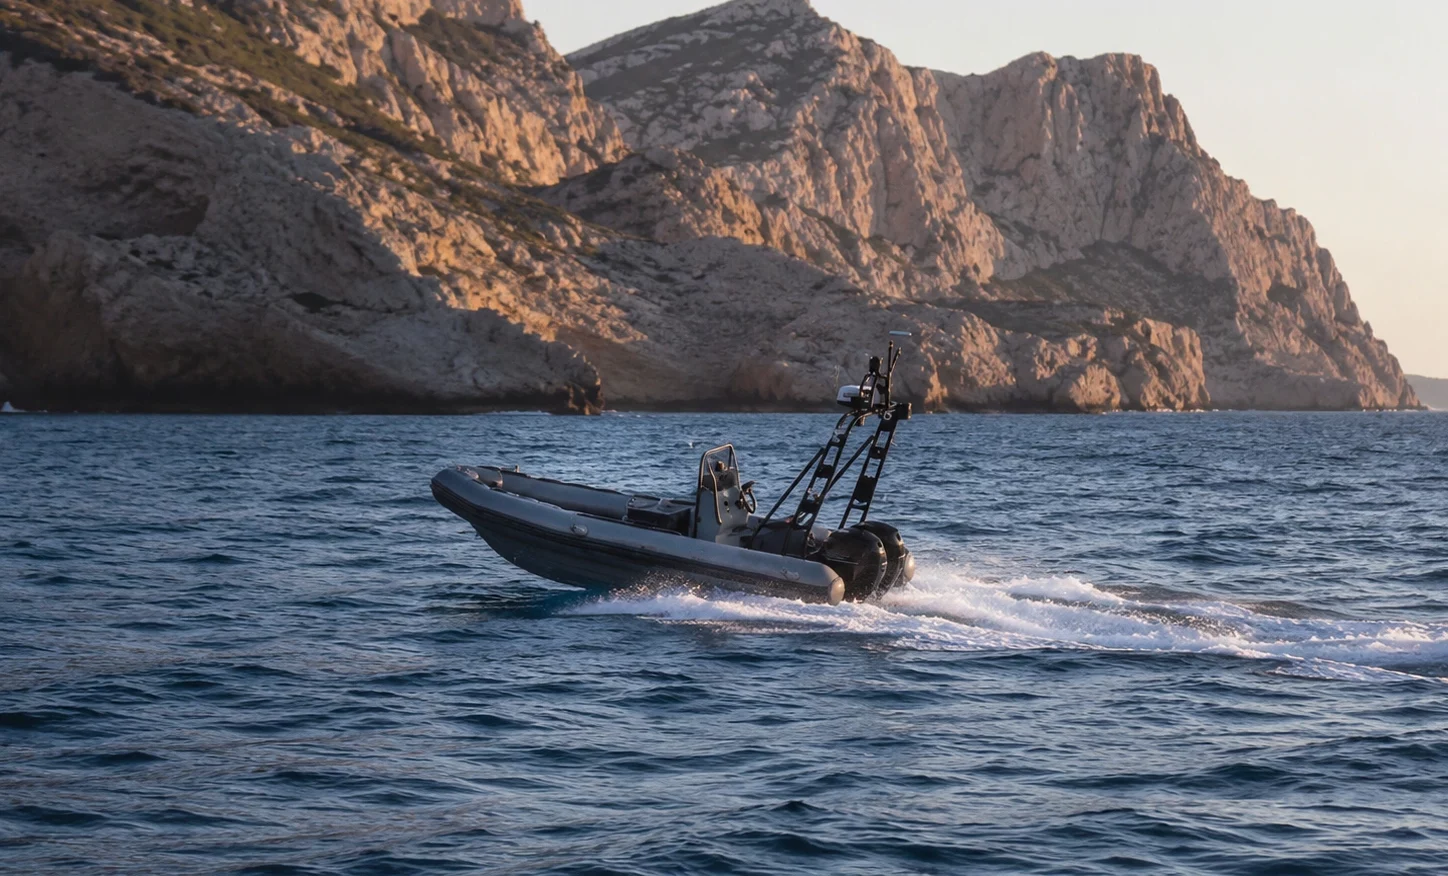
Autonomy conversion for suitable existing vessels.

HADDAD

Purpose-built uncrewed surface vessel.

ARES + ARMATURE

Autonomy aboard the platform. Integration across the operation.

ARES manages onboard autonomy for applicable ground vehicles and surface vessels.

ARMATURE provides the middleware layer between supported platforms, mission systems and customer command systems.

Together, they allow platform autonomy and wider system integration to be considered within one technical approach.

Define the autonomy requirement.

Tell us about the vehicle or vessel, its existing controls and the intended operating role.
We can discuss autonomy functions, platform interfaces, operating modes and the evaluation required to establish a suitable approach.