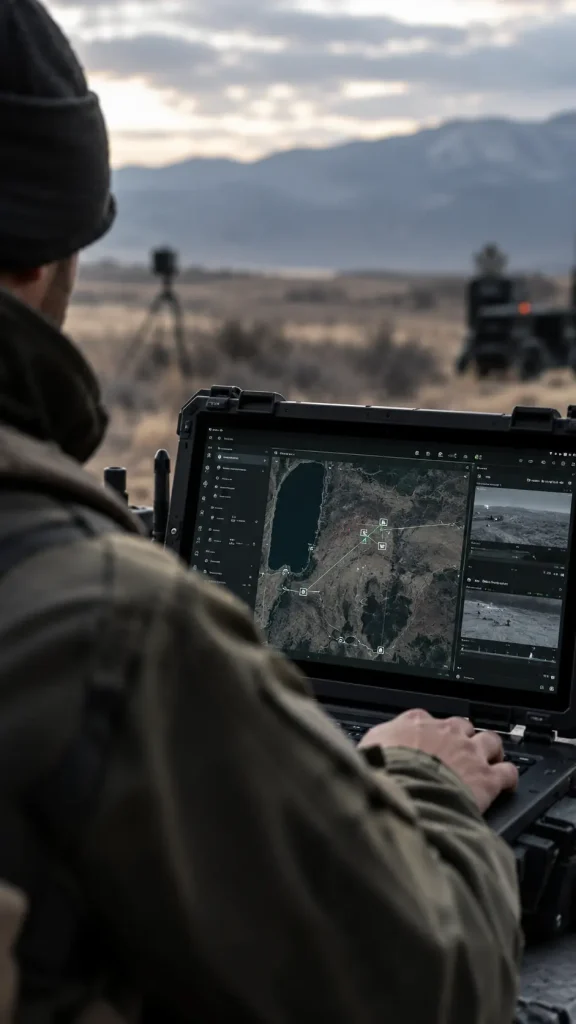
MAS brings together autonomy, platform engineering and systems integration around the mission.
Platforms, software, sensors, mission equipment and command interfaces are considered together, with development shaped by the operating environment, existing architecture and intended task.
Onboard autonomy for applicable ground vehicles and surface vessels, integrating platform control, navigation, mission systems and operator command.
Cross-domain middleware connecting supported platforms, mission systems and command environments for tasking, coordination and information exchange.